Robot perception for decision-making: turning multimodal sensor data into representations of the world that robots can act on for navigation and planning.
Ph.D. student in Electrical and Computer Engineering at Rochester Institute of Technology and Graduate Research Assistant in KAS Lab, advised by Prof. Mohammad Javad Khojasteh. Current research focuses on perception that withstands sensor degradation on underwater robots, fusing camera and sonar so that an AUV keeps perceiving its surroundings as visibility drops. Broader interests include world models (JEPA), diffusion models for planning, and MPC driven by learned perception.
Nine years of experience deploying perception on physical robots: quad-rotors, field rovers and AUVs. Previously, four and a half years at Intel Labs, architecting a real-time multimodal perception system taken from research prototype to deployment in three semiconductor fabs worldwide.
Robot perception underwater, on the ground, in the air, and in the fab.
01 / ONE INSTANT, TWO SENSORS · TRY ITREAL TEST FRAME
CAMERACAMERA
CAMERACLEAR WATER
ALSO SEEN BY CAMERA
FL SONARUNAFFECTED
OBJECTS FOUND
2 / 2
BY CAMERA
2
RECOVERED BY SONAR
0
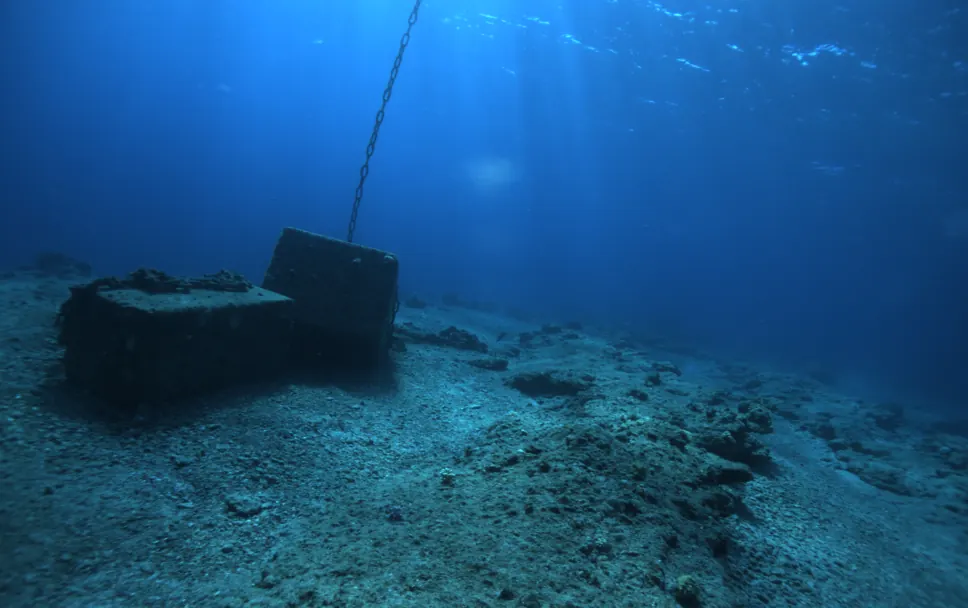
Clear water: the camera finds both objects, and the sonar detects 1 of them too.
Detected by the camera
Recovered by sonar when the camera misses it
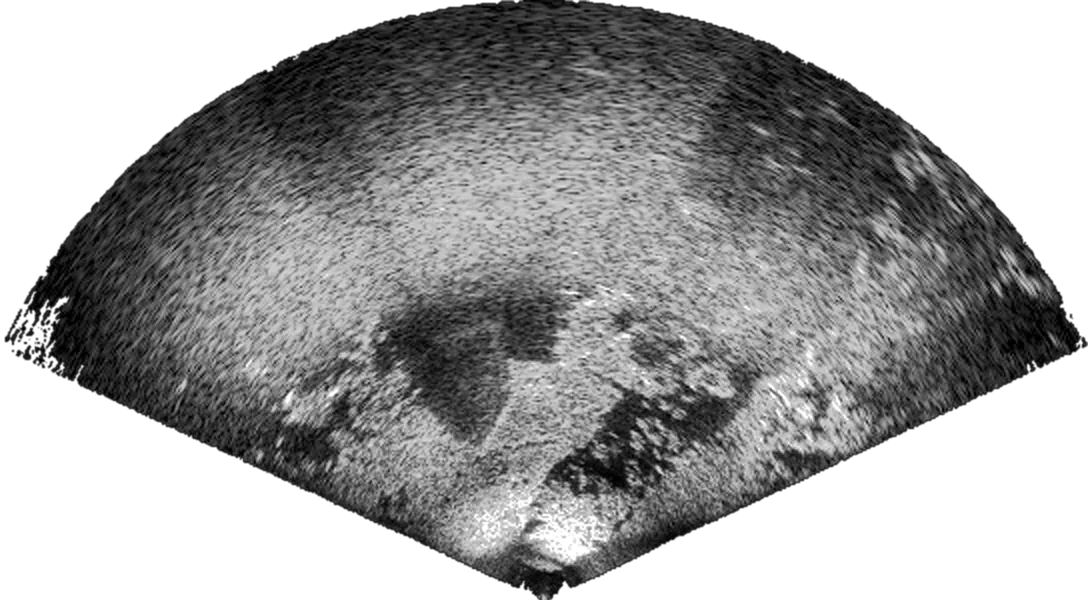
Where the sonar says it likely is (sonar has no height, so it’s a zone, not a box)
Real test frame · the model’s own detections (seed 0) · under review
MULTIMODAL PERCEPTION/01
RGB–sonar fusion under camera degradation
Cameras fail underwater in exactly the conditions where an AUV most needs to see. This RGB–forward-looking-sonar detector weights each modality by how degraded the visual input is, relying on sonar in darkness or turbidity and on the camera in clear water. Objects the camera loses are recovered from the sonar and projected into the image as likely zones, since sonar measures bearing and range but not elevation.
RGB + FL sonar
Adaptive fusion
Object detection
AUV
20.1%
recall in heavy darkness, up from 0.3% camera-only
53.6%
mean recall on degraded imagery
No loss
in clear water
KAS Lab · RIT / 2026 · under review
02 / SIMULATION REPLAY · TOP-DOWNSIMULATION RUN
t = 82.8 snearest 3.00 m · contact at 0.9 mNOMINAL MPC
CBF MARGIN h(t) · MIN 1.86 > 0
AUV
Filter active
Moving obstacle (point mass)
+Waypoint
Python sim · Fossen 4-DoF AUV held at one depth · 3× speed
SAFE AUTONOMY/02
Safe AUV navigation among moving obstacles
A model-predictive controller tracks waypoints on the 4-DoF Fossen model of a BlueROV2, while a control-barrier-function filter corrects each command, when needed, to the closest safe one around moving obstacles, with a margin sized to how hard each obstacle can accelerate. Evaluated in ROS 2 / Gazebo; the replay runs the same controller in a planar Python simulation. A multi-agent extension is in progress.
MPC + CBF
ROS 2 / Gazebo
4-DoF Fossen model
BlueROV2
3 / 3
logged Gazebo courses completed
0
collisions or safety-margin violations
1.41 m
closest approach, against contact at 0.9 m
KAS Lab · RIT / 2026 · ongoing · simulation
03 / HOW IT WORKSCONCEPT ILLUSTRATION
DENOISING STEP k = 00 / 40
Noiserandom controls
Denoise1D U-Net (DDPM)
CBF guidance∇h at every step
Controls → Fossen8 s plan
Guided sample
Where it would go unguided
Concept illustration · not experimental data
GENERATIVE PLANNING · EXPLORATORY/03
CBF-guided diffusion planning
A 1D-convolutional U-Net (DDPM) generates 8-second control sequences for an AUV, integrated through a differentiable port of the 4-DoF Fossen dynamics. Trained only on obstacle-free MPC rollouts, it is steered at sampling time by a braking-distance control barrier function, so it avoids obstacles it never saw in training without retraining. In a first scenario every guided sample stays clear of the obstacle; collision-rate statistics are still to come.
Diffusion (DDPM)
CBF guidance
PyTorch
Fossen dynamics
8 s
control plan per sample, 80 steps
0
obstacles in the training data; the CBF steers sampling
5.2 → 0.9 m
median held-out goal error, with goal conditioning
KAS Lab · RIT / 2026 · exploratory
04 / FROM DEMONSTRATION TO GUIDANCECONCEPT ILLUSTRATION
PROCESS SPEC · TIMESTAMPED BY VOICE
Open the chamber00:41
Remove the module02:13
Inspect under the microscope04:52
Fit the new module06:30
Close and verify07:58
TEACHING MODE · BY VOICE
TECH“Step done.”speech to text
MARIELogged step 5 at 07:58.→ label
Timestamps become labels: MARIE retrains on the new demonstration
Concept illustration · generic procedure, not Intel data
MULTIMODAL LEARNING · DEPLOYED/04
MARIE: multimodal activity recognition
MARIE (Multimodal Activity Recognition in an Industrial Environment) is an AI performance-support system that guides technicians through multi-step procedures, combining real-time multimodal action recognition with learning from expert demonstrations in a human-in-the-loop framework, so that it improves with use. Architected end to end, including explainability and multilingual voice interfaces, and rolled out across three fabs.
IN THE FIELD · ZED MINI ON THE ROVERFIELD MAP · 5 ROWS · RIPENESS BY POSITION
FIELD MAPPED
Lab a* channel
Threshold
Contour + box
CNN check
R-channel ripeness
Stereo → 3D
One pass per row. Every strawberry is placed on the map with its ripeness level.
L1 · unripe · 16
L2 · turning · 19
L3 · ripe · 57
Concept illustration · results from the published paper
FIELD ROBOTICS/05
Strawberry detection and 3D field mapping
An autonomous UGV that maps a working strawberry field in 3D. CIE-Lab color analysis proposes candidate regions, a MobileNetV2 onboard a Jetson AGX Xavier rejects false positives, the red channel grades ripeness in three levels, and ZED Mini stereo places each fruit in space. The map shows crop status and reveals zones of uneven maturity that may point to nutrient, pest or irrigation problems.
UGV
CIE-Lab
MobileNetV2
ZED Mini stereo
93.8%
of 272 test strawberries correctly detected and classified
16 / 22
ripe fruit found in the field, vs 14 for a 2022 baseline
ONBOARD CAMERA · JETSON TX2EXTERNAL VIEW · TOP-DOWN
FLIGHT COMMAND · MAVLINK
Roll
hold
Thrust
hold
Pitch
holdbox 56 / 58 px
send_ned_velocity(0.00, 0.00, 0.00)
Upper body
Face
Slow zone
Fast zone
Concept illustration · control logic from the published paper
AERIAL ROBOTICS/06
Onboard person tracking for a quadrotor
An autonomous quadrotor for person following, intended for applications such as surveillance. Onboard a Jetson TX2, one Haar cascade detects the upper body and a second searches for the face only within it. The position of the face in the image is mapped to roll and thrust commands, and the width of the detection box to forward pitch, sent over MAVLink to an ArduCopter flight controller. Validated in outdoor flight tests.
Haar cascades
Jetson TX2
DroneKit / MAVLink
ArduCopter
0
false upper-body + face detections in flight tests
2-stage
detection: upper body first, then the face within it
R. Manuvinakurike, S. Biswas, G. Raffa, R. Beckwith, A. Rhodes, M. Shi, G. Mejia, et al.
SCAI Workshop at SIGIR
04 / EXPERIENCE & EDUCATIONTHE PATH SO FAR
From building to understanding.
Nine years of putting perception on physical robots and into deployment, from a quadrotor to semiconductor fabs to AUVs.
EDUCATION
MAY 2026 — PRESENT
Ph.D. · Electrical & Computer Engineering
Rochester Institute of Technology
Fully funded graduate research assistantship2019 — 2021
M.Sc. · Mechatronics
Centro de Investigaciones en Óptica
Specialization in path planning for robotics2015 — 2019
B.Eng. · Mechatronics
Universidad Tecnológica de León
Minor in Optics
2026 — PRESENT
KAS Lab · Rochester Institute of Technology
Graduate Research Assistant · Advisor: Prof. Mohammad Javad Khojasteh
Perception under sensor degradation for AUVs: an RGB–forward-looking-sonar fusion detector that keeps the robot seeing when the camera fails. Ongoing: MPC with a control-barrier-function safety filter for AUV navigation among moving obstacles.
OCT 2021 — APR 2026
Intel Labs · Intelligent Systems Research Lab
Software Research Engineer / Scientist
Architected MARIE, a real-time multimodal action-recognition system learned from expert demonstrations and deployed across three fabs. Built C++ ROS point-cloud perception and 6-DoF pose estimation for Kidspace.
2019 — 2021
Robotics & Perception Lab · CIO
M.Sc. Researcher
Deep RL for obstacle avoidance in 6-DoF pick-and-place and UAV navigation in unknown environments; a stereo-camera rover on NVIDIA Jetson for strawberry detection and ripeness estimation.
2017 — 2019
Robotics & Perception Lab · CIO
Undergraduate Research Assistant
Real-time face detection and person-following control, flight-tested on a physical quad-rotor UAV.
RGB–sonar fusion that keeps an AUV detecting objects in darkness and turbidity; multimodal action recognition deployed in three fabs; stereo perception on a field UGV.
NEXT
Perception that estimates how far to trust each sensor, across RGB, depth, sonar and audio, and passes that confidence on to the planner.
02Safe planning and navigation
SO FAR
MPC with control-barrier-function safety filters for AUV navigation among moving obstacles; CBF-guided diffusion planning, at an exploratory stage.
NEXT
Decentralized multi-agent navigation, and planners that act directly on perceived, uncertain scenes.
03World models for planning
SO FAR
No published work yet; the diffusion planner is the nearest groundwork.
NEXT
Predictive latent representations of the world, grounded in multimodal perception, that a planner can act on.
06 / GET IN TOUCHLET’S BUILD SOMETHING MEANINGFUL
Have a question, an idea, or a research opportunity?